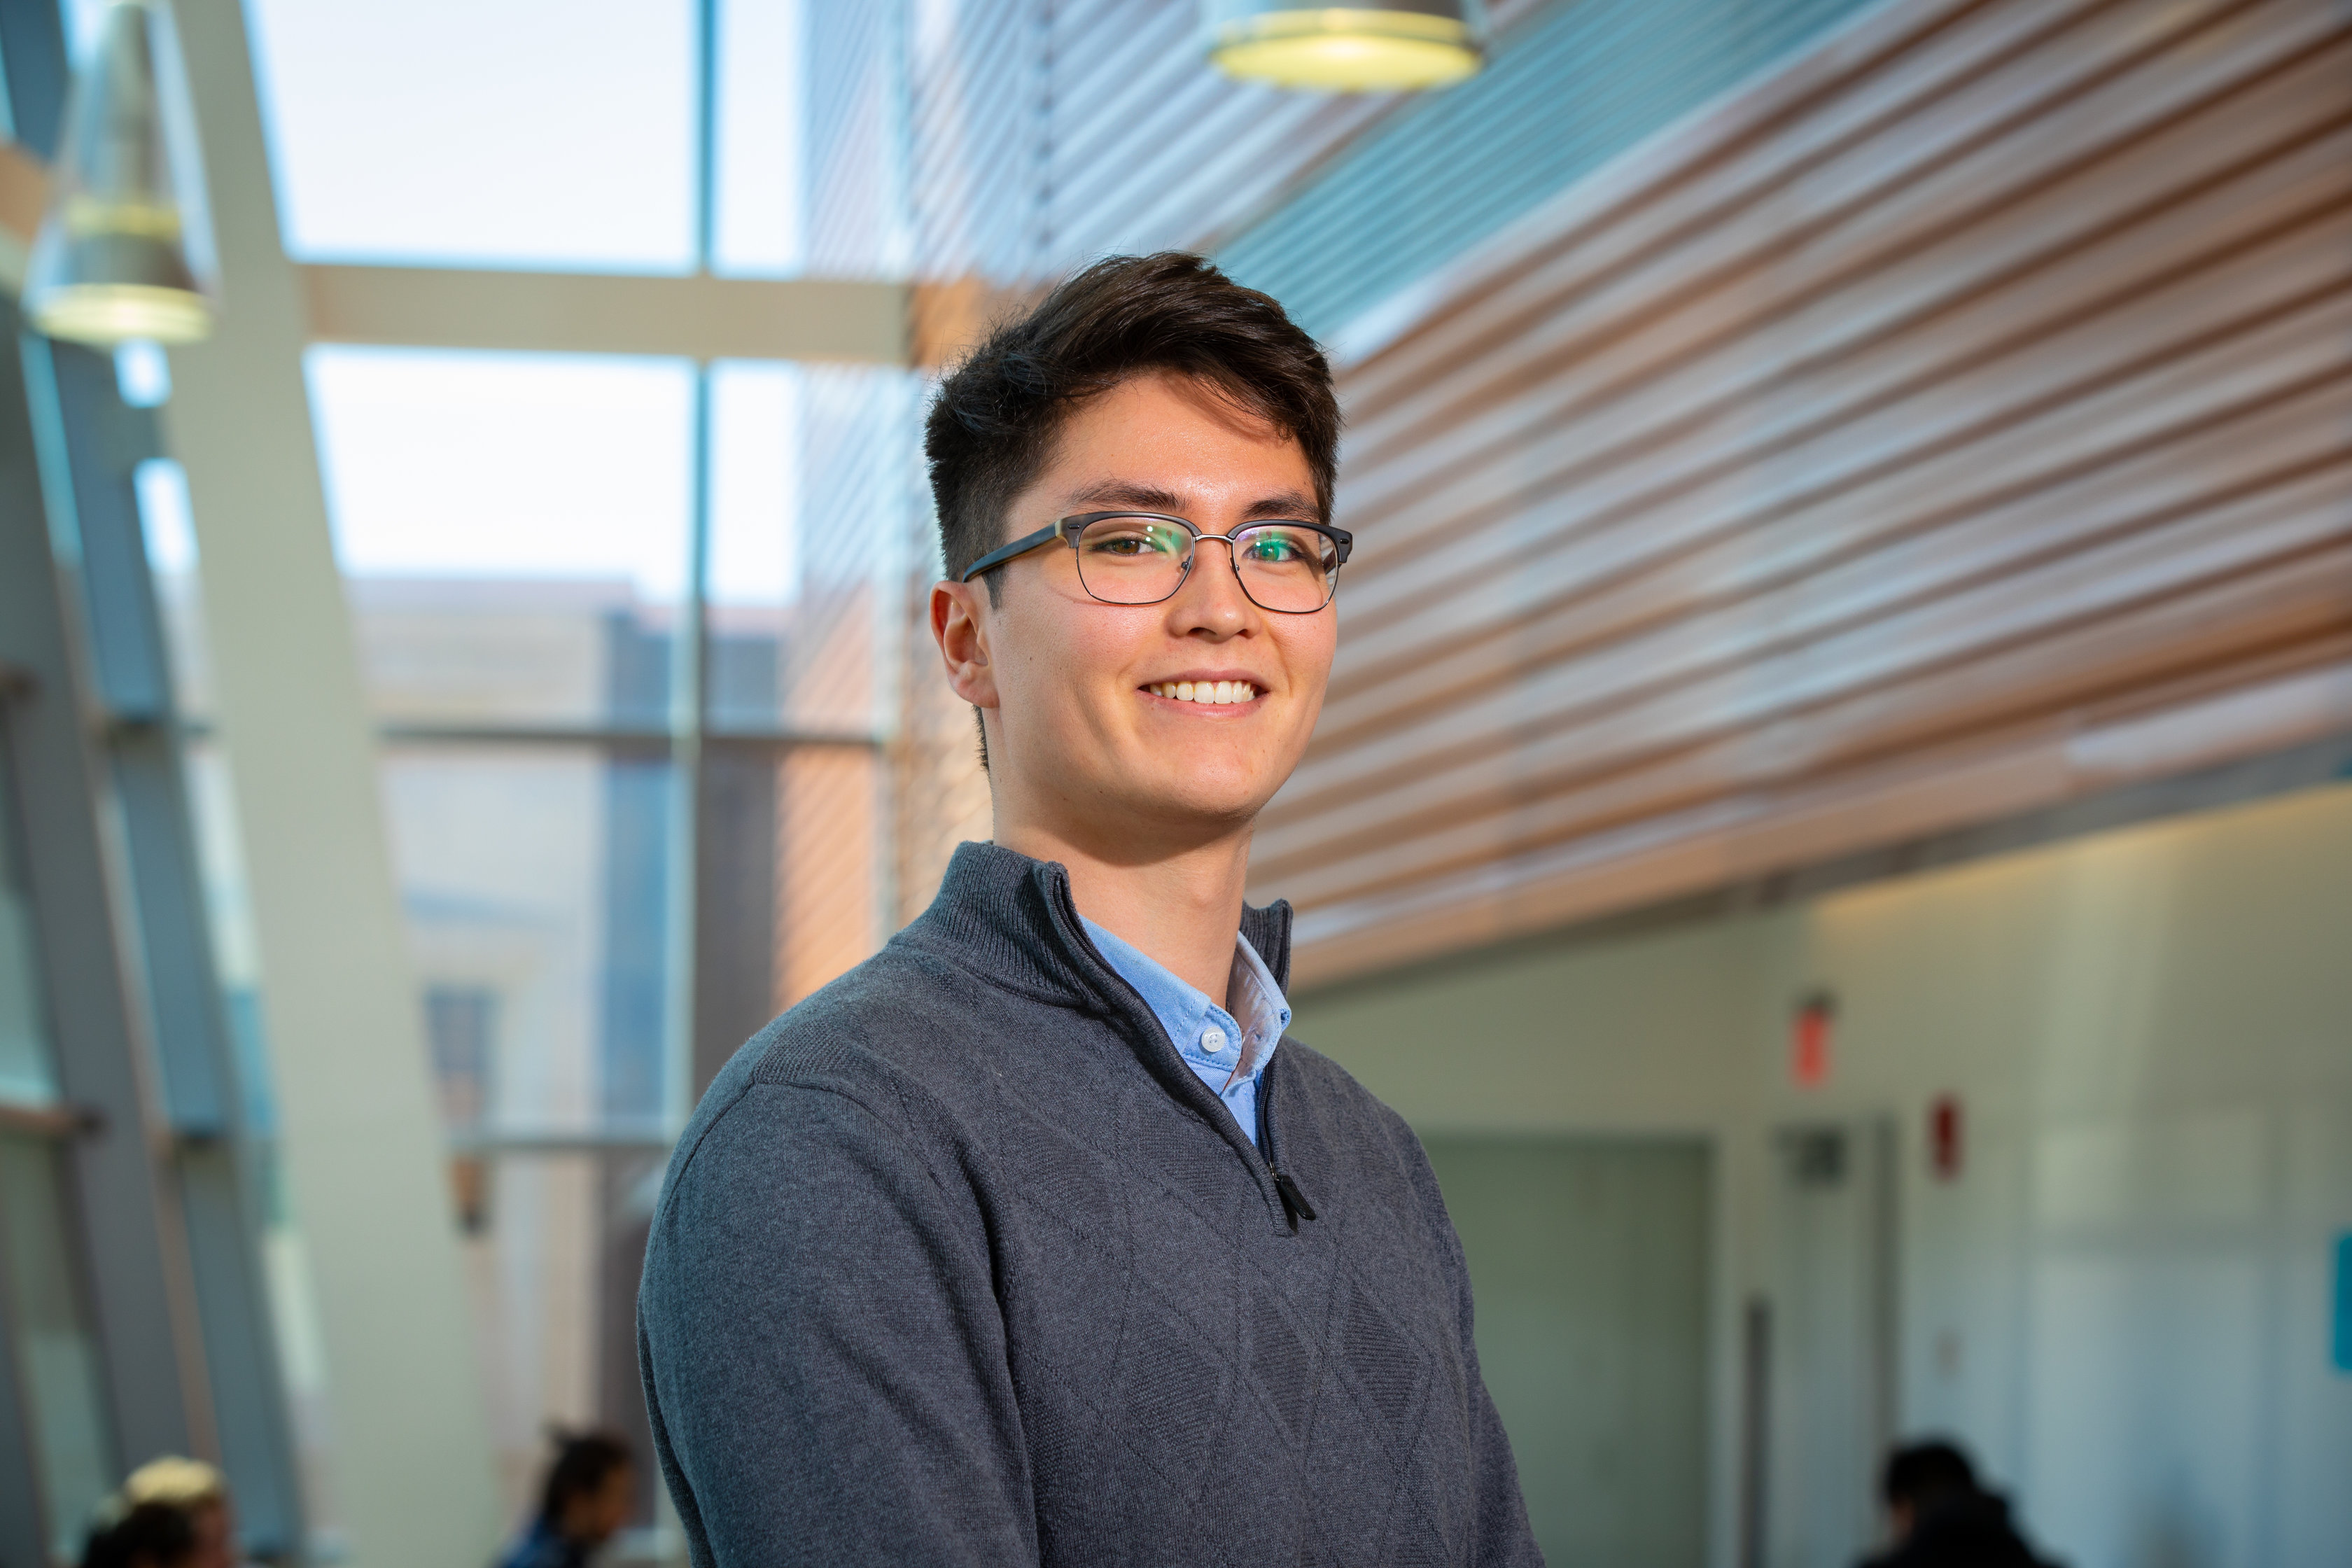
Javier Yu |
I'm a research scientist at Toyota Research Institute, where I build end-to-end multimodal models for autonomous vehicles. As a roboticist, I'm interested in practical solutions for problems at the intersection of learning and perception. Recently, my work has focused on architecture design, post-training, and deployment of driving policies. Before joining TRI, I completed a Ph.D. in Aeronautics and Astronautics at Stanford University. I was advised by Professor Mac Schwager as part of the Multi-robot Systems Lab and was supported by an NSF Graduate Research Fellowship. linkedin / google scholar / github / resume email: |
|
Recent preprints |
|